Murad Malik · [email protected] · muradmalik.com · linkedin.com/in/muradmalik

Projects

The result, the numbers, and the figures for each project. Open one to see how it was designed, tested, and built.

The Push Back robot, number 2147Z, on the VEX World Championship stage between blue and red lit arches.
Oct 2025 to Apr 2026

Push Back robot, V5RC 2025-26

Our robot went to the VEX World Championship for Southern California, finished in the top 8% of teams there, and ranked #33 in the world in programming skills.

  • #33world ranking in programming skills
  • Top 8%of all teams at the World Championship
  • 6 awardsin the Push Back season
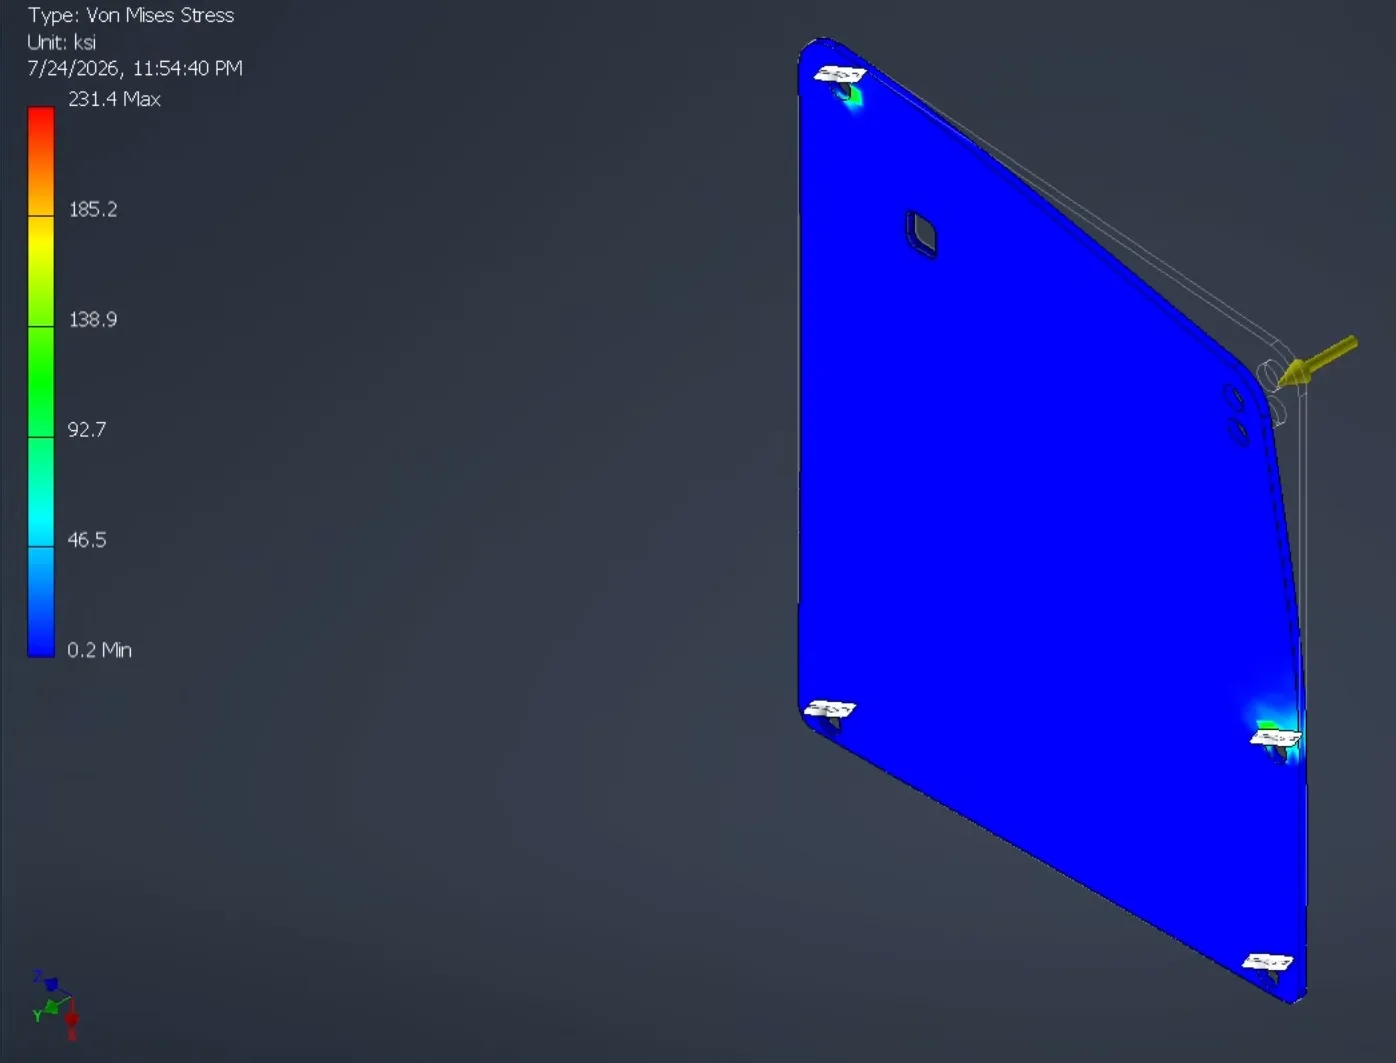
  • FEA plot of the front drive endcap, mostly blue with small colored areas at the bolt holes.FEA, front drive endcaps
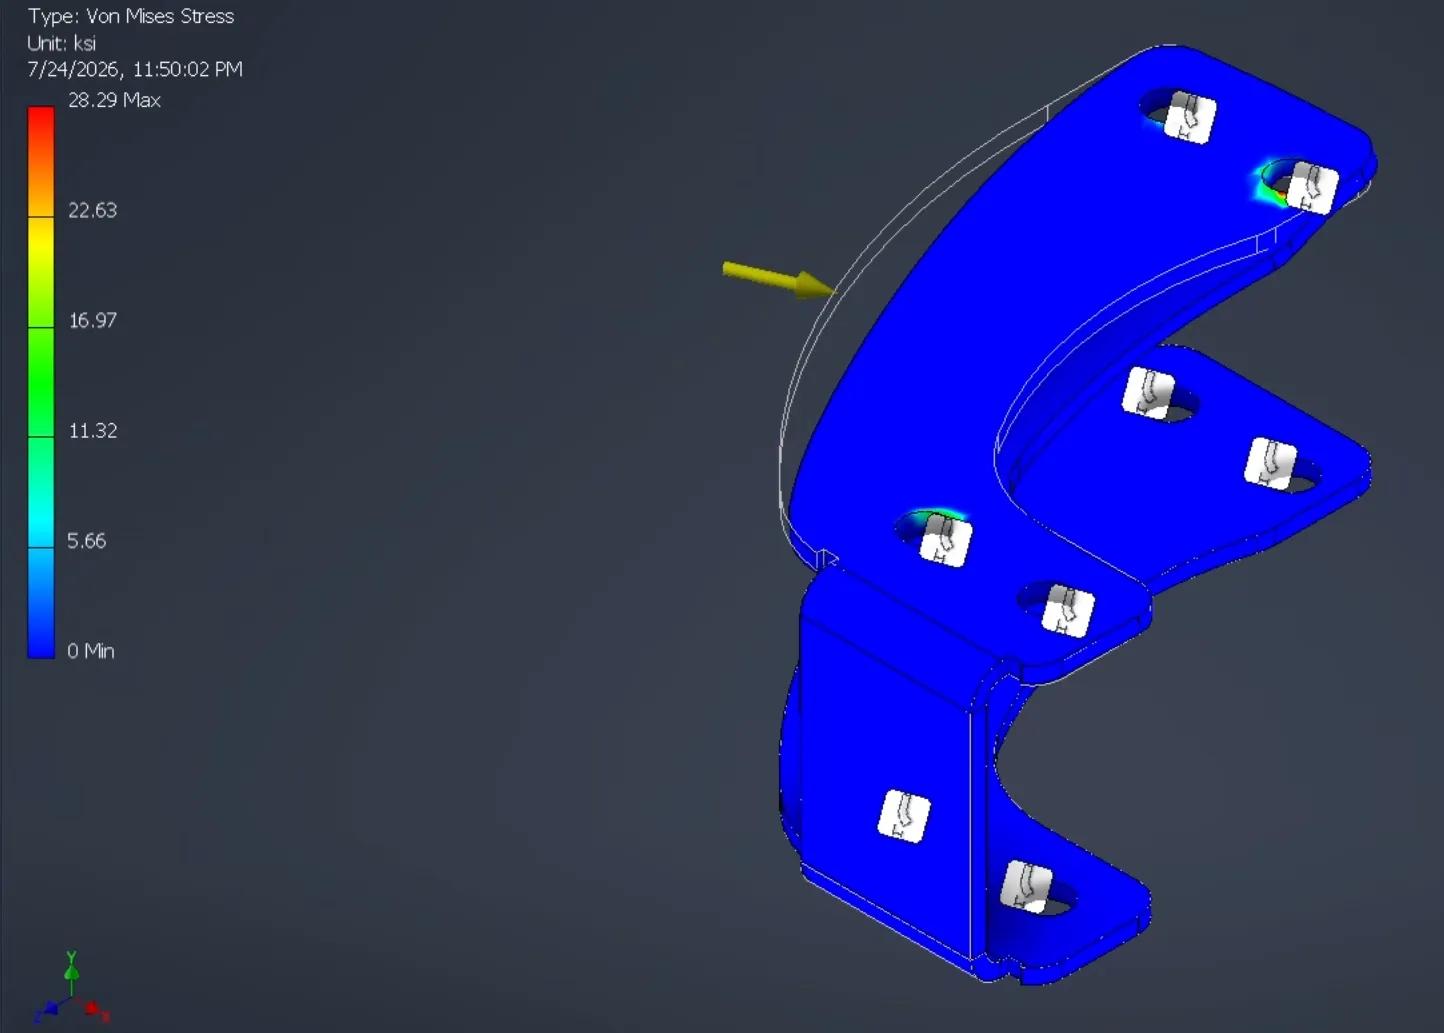
  • FEA plot of the top intake plate, mostly blue with small colored areas at the mounting points.FEA, top intake plate
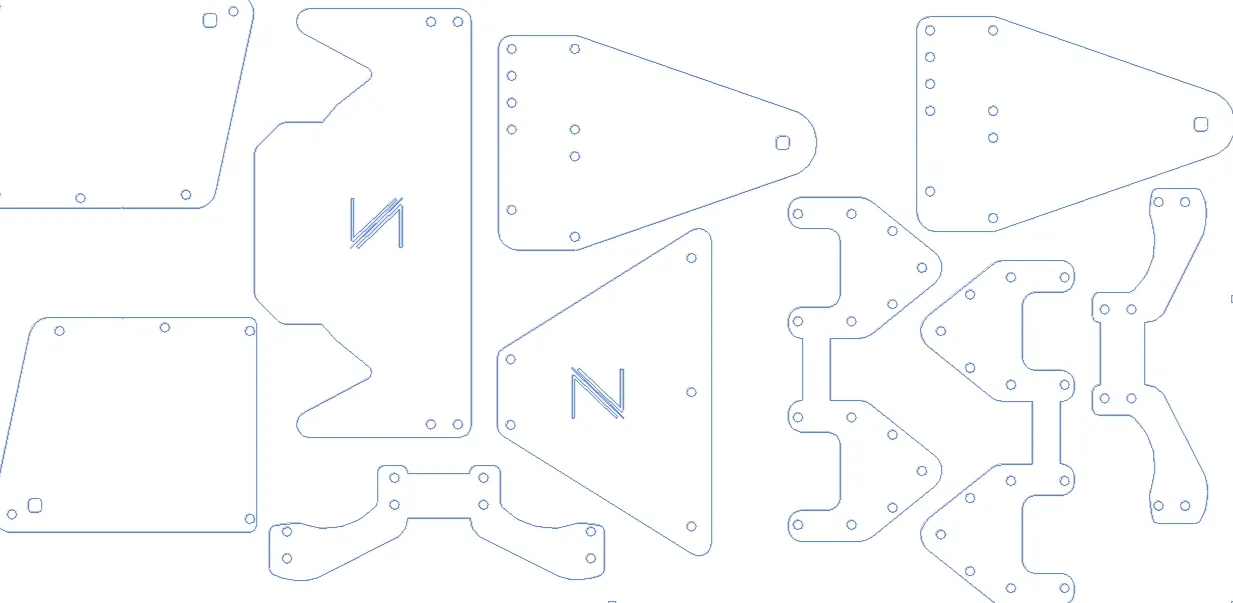
  • Line drawing of many polycarbonate parts nested closely on one sheet.Cut file, nested in Deepnest
View project
The High Stakes robot, a red and black frame with a tall lift, on a practice field with checkered walls.
Sep 2024 to May 2025

High Stakes robot, VRC 2024-25

Won 13 awards in the 2024-25 season, including 3 Excellence Awards, 2 Tournament Champion titles, and the Design Award that qualified the team for the World Championship.

  • 13awards in the 2024-25 season
  • 21tuned autonomous routines, written with a tool I built
  1. Excellence3
  2. Tournament Champion2
  3. Innovate2
  4. Judges2
  5. Design (qualified for Worlds)1
  6. Amaze1
  7. Robot Skills Champion1
  8. Special recognition, VEX AI Worlds1

Awards by type in the 2024-25 season, 13 in total

View project
Summer 2025

Logo tooling part, Ascent Aerospace

A logo tooling part printed in ABS on a large-format printer, then CNC milled to its final dimensions.

Role
Intern team member
Material
ABS
Process
Large-scale additive manufacturing, then CNC milling
View project
A dark poster that reads autoBuilder, with a field showing a dashed robot path, a controller screen showing Point Goal, a terminal with a printed line of code, and a row of command names.
Apr 2025 to Oct 2026

autoBuilder, a PROS library for writing autonomous routines

A tool we used to write 21 autonomous routines for our High Stakes robot is now a PROS library. A team supplies command templates and one function that reports its robot's state, and the library prints the finished code.

  • 21autonomous routines written with the first version
  • 1function a team writes to report its robot's state
  • 0drivetrain calls inside the library
  • v1.0.0first PROS template, built May 2025
  • Two panels. On the left, a main.cpp box holding five robot-specific parts. On the right, a library box that takes a command list, a snapshot function, and the controller and screens.Logic in main.cpp, then in the library
  • Three cards for April 2025, May 2025, and October 2026, each showing the autoBuilder constructor at that commit.The constructor across three versions
View project
Jun 2026 to present

SSHand

An open-source tool that lets AI agents run commands and move files on remote machines over SSH. It has 11 tools and 28 tests that run against real SSH connections, and it is on PyPI.

View on GitHub
Apr 2026 to present

Rent collection platform

Rent collection and tenant management software for a property management company with roughly 50 to 60 tenants.